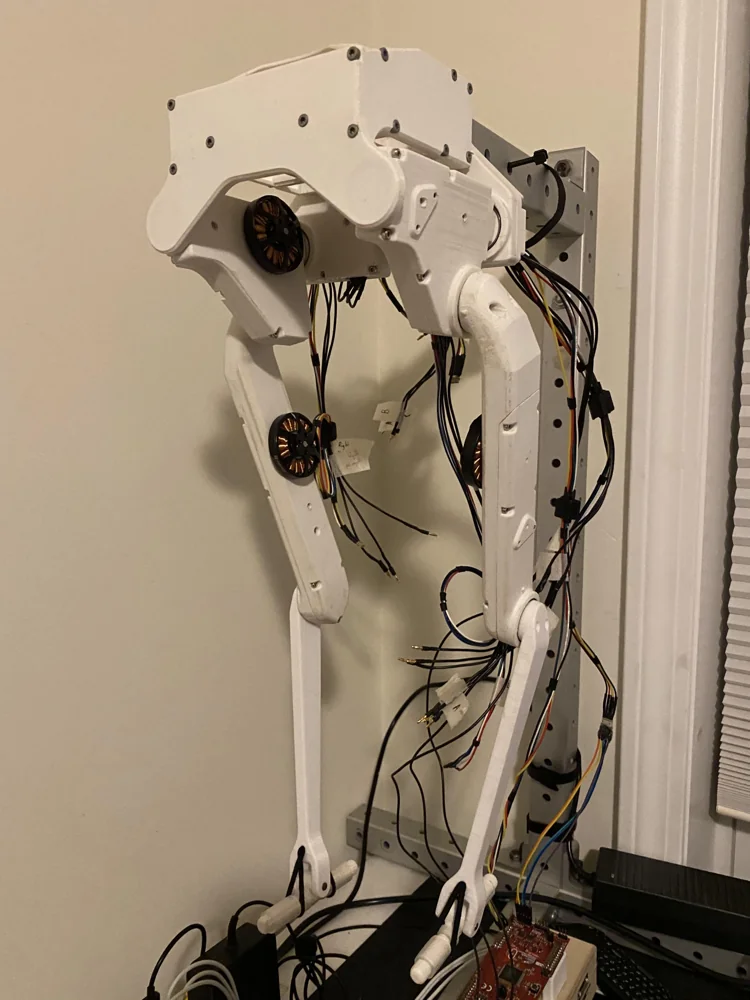
ODRI Biped
Building my own open source ODRI biped to better understand bipedal robotics control from the low level hardware to the high level simulation and controls.
Building my own open source ODRI biped to better understand bipedal robotics control from the low level hardware to the high level simulation and controls.

RL agent playing SuperTuxKart
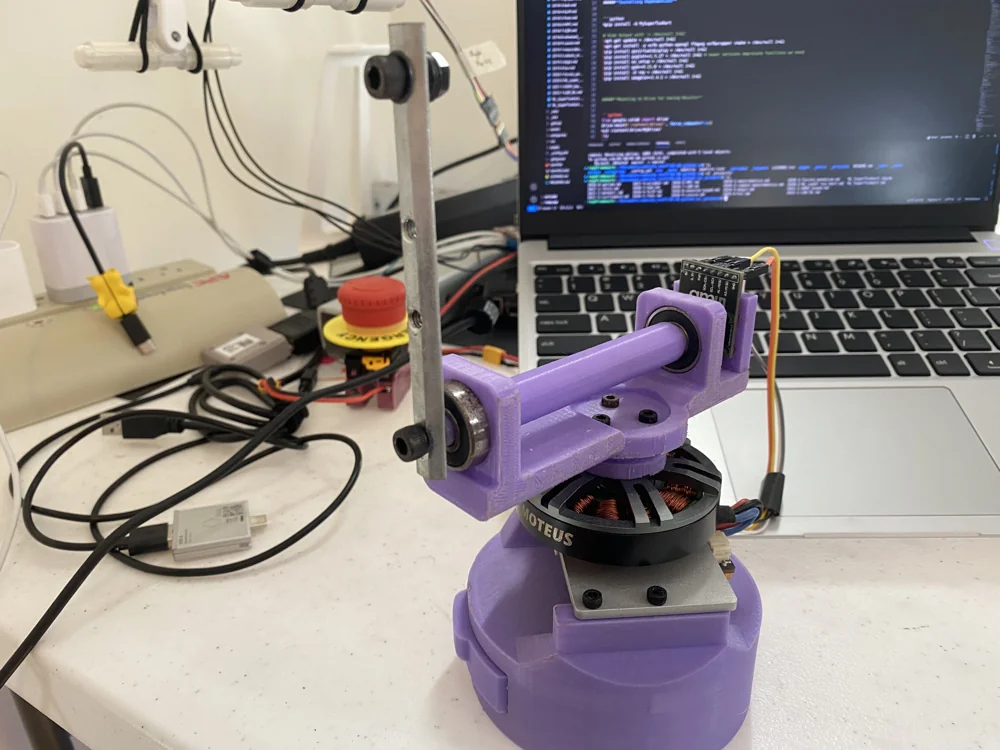
Energy Shaping & LQR for Furuta Pendulum
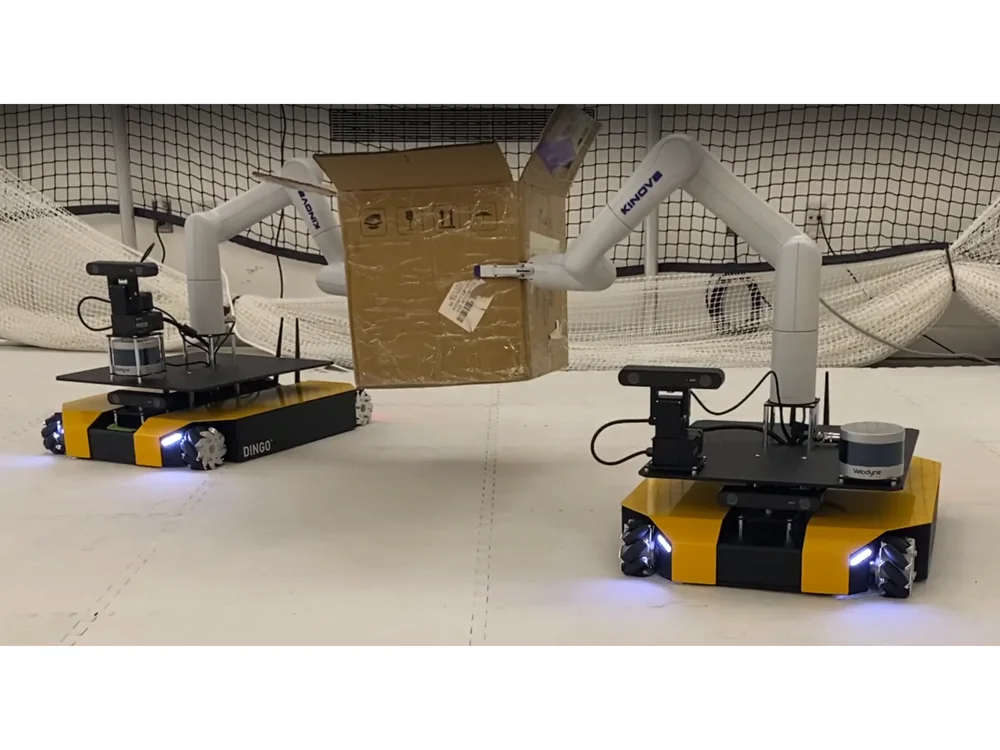
Research into multi-mobile manipulation control for dual lift tasks.
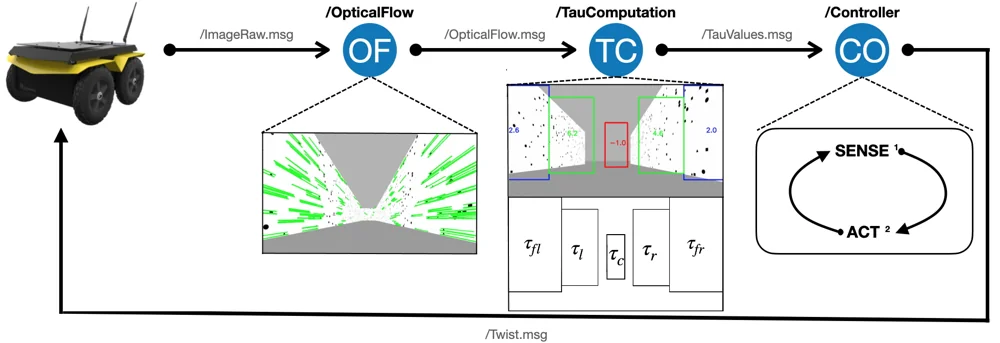
Research into optical flow during my time with Dr. John Baillieul at BU.
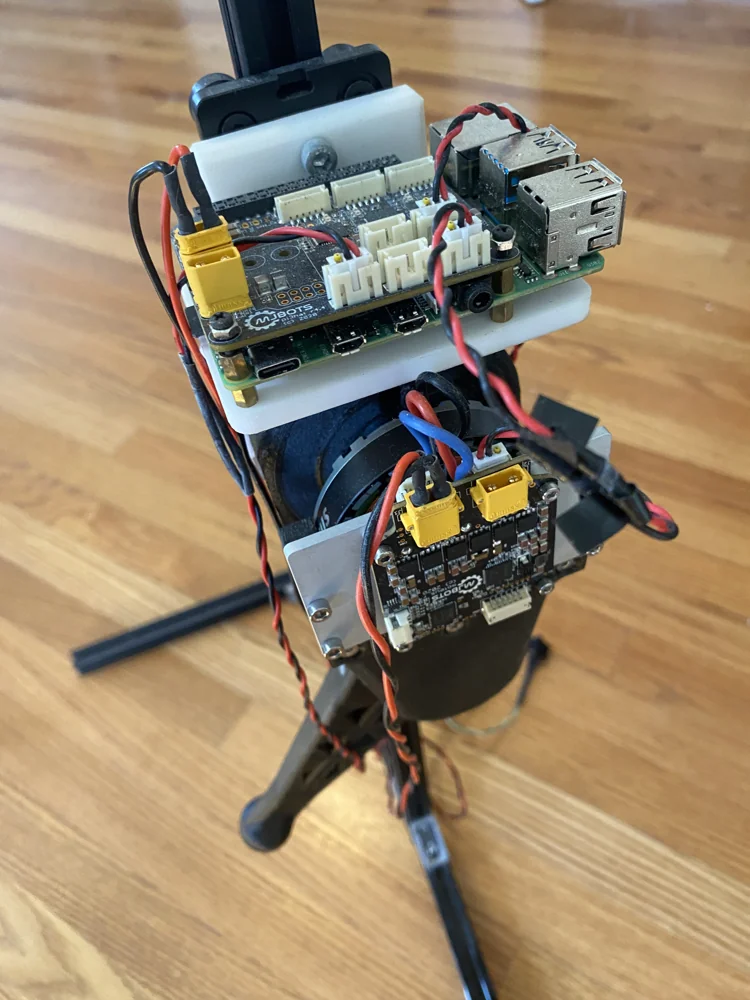
Test leg I designed for experiments
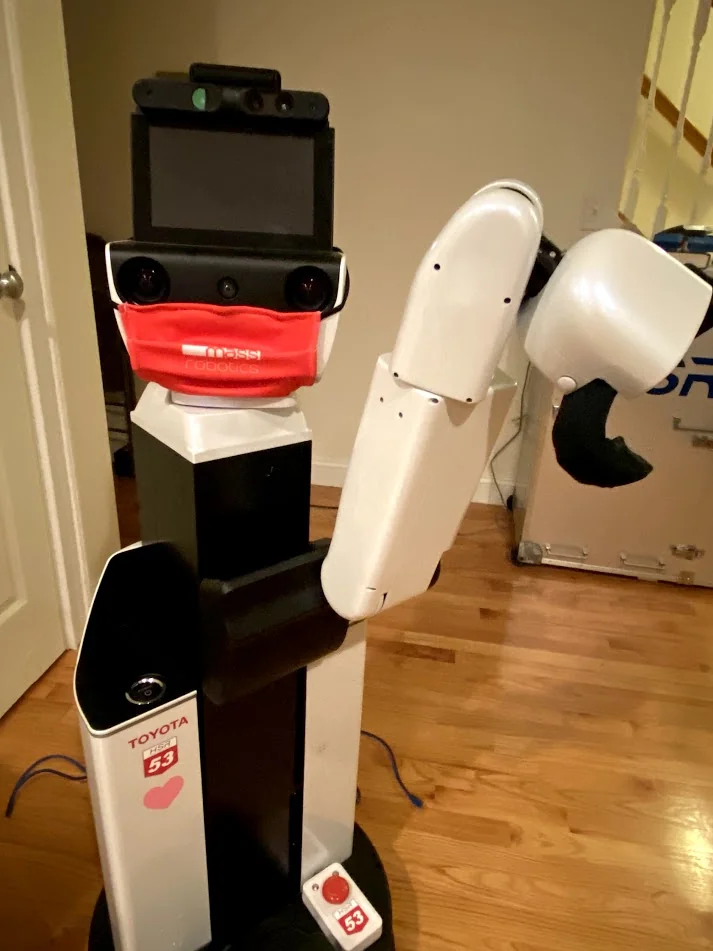
Personal robot from Toyota
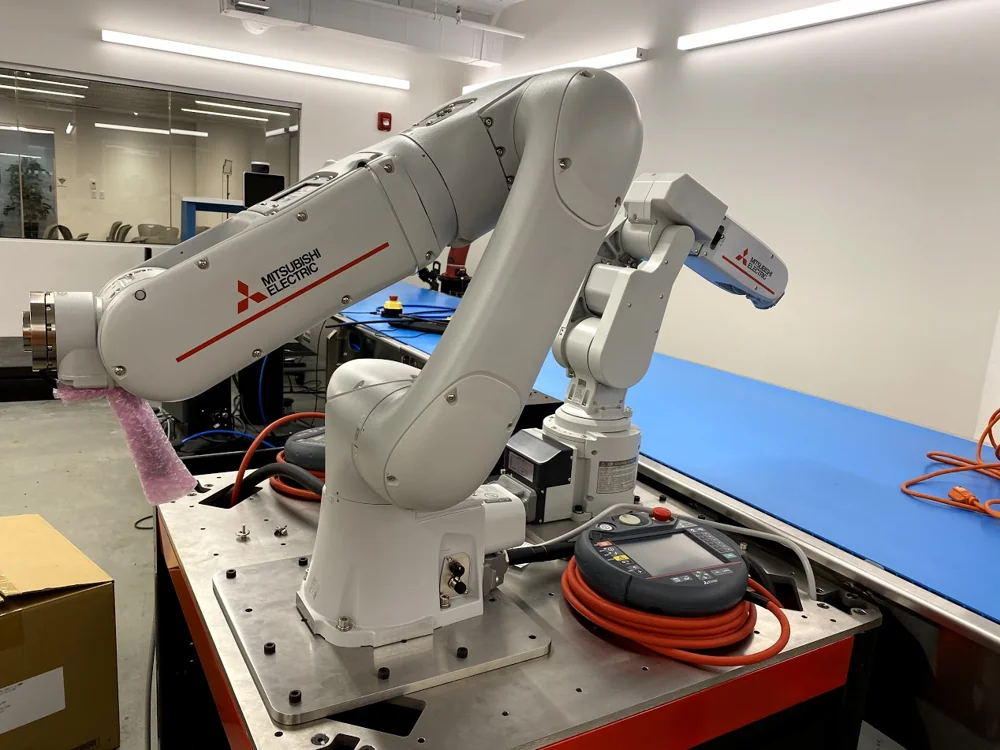
Maintaining and programming robotic arms at MassRobotics
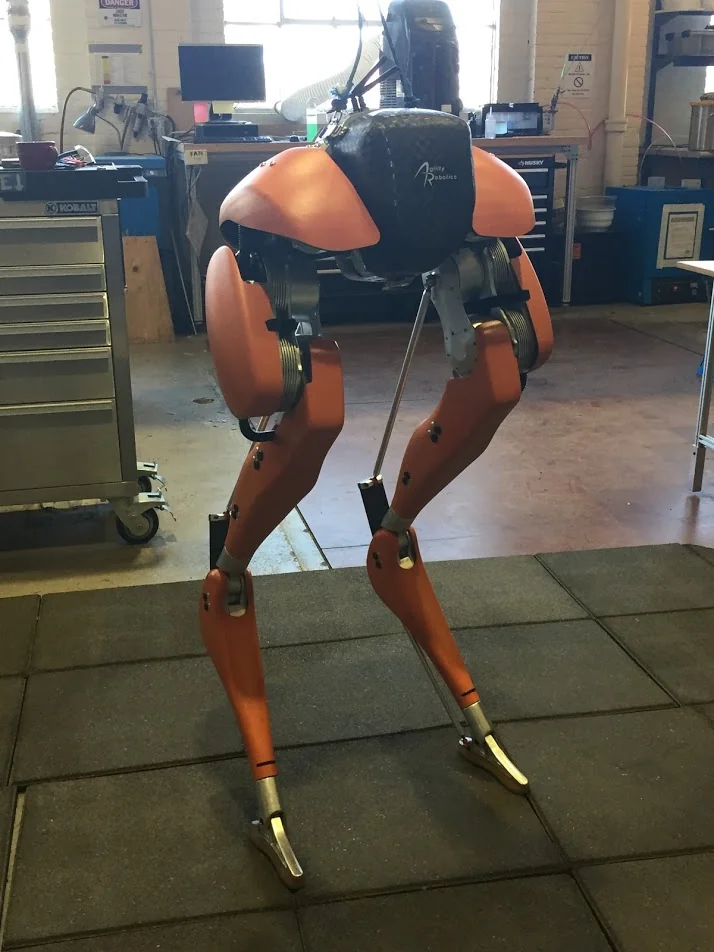
Dynamic Locomotion Robotics Research
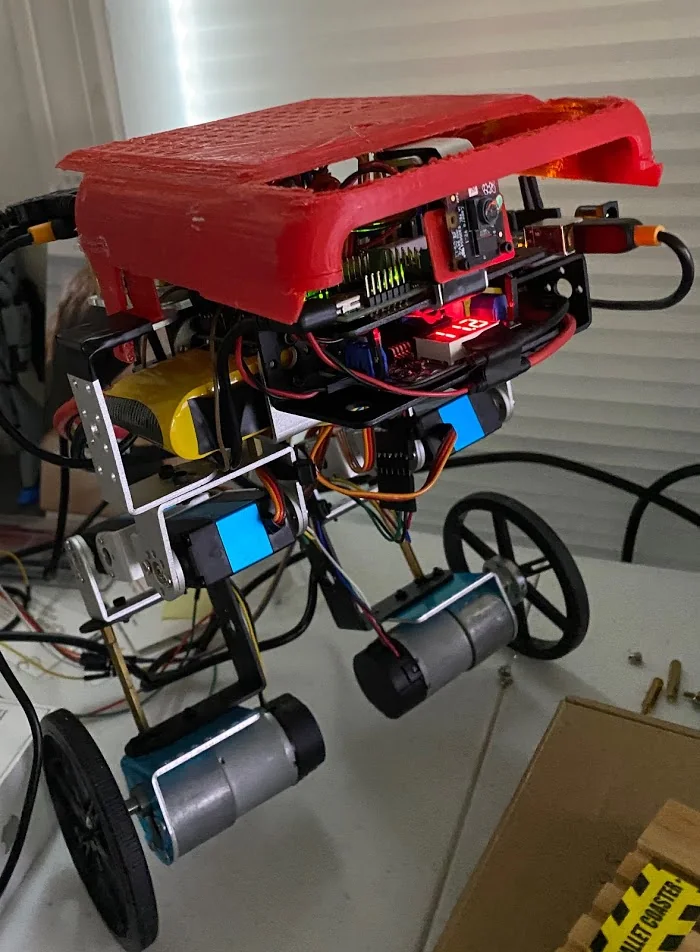
Roller Wheels Bipedal Robot
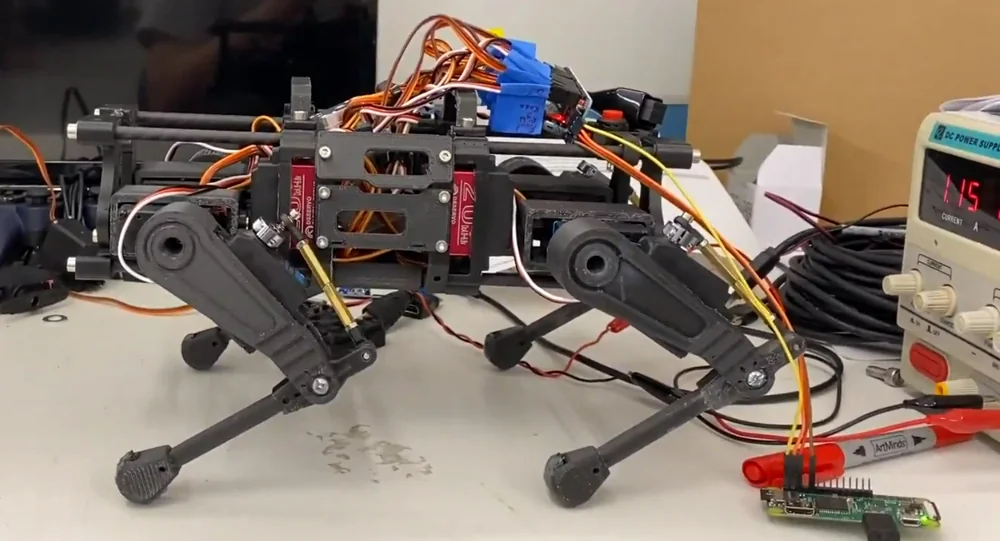
Designed my own little servo quadruped robot
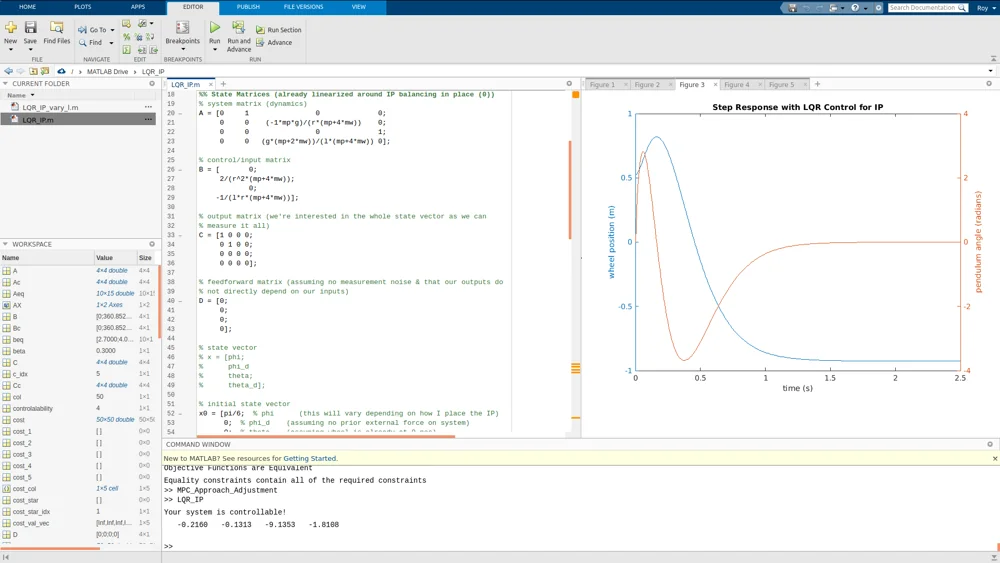
cartpole LQR
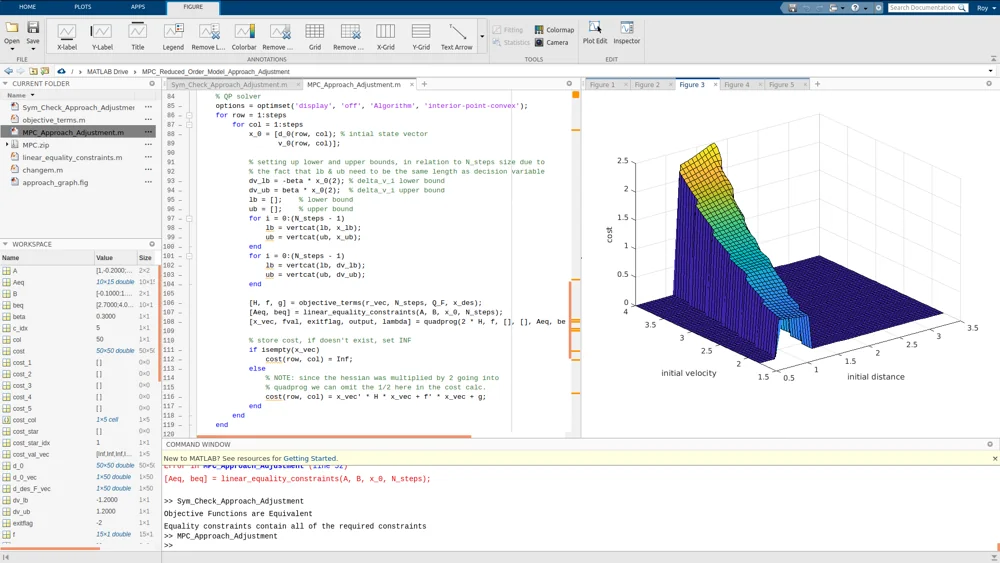
Summer research on MPC for future bipedal Cassie controllers
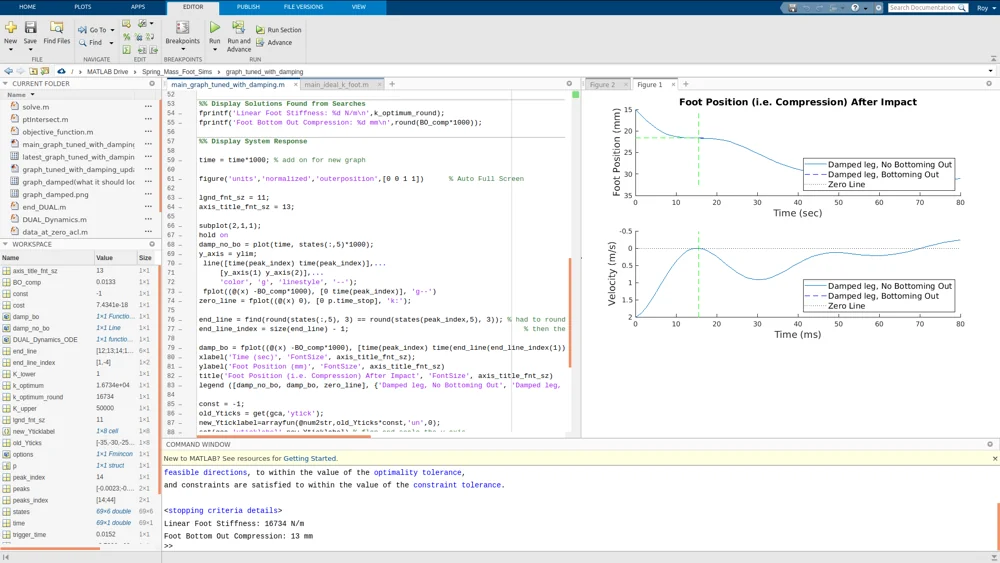
Work on paper and journal for research on impact dynamics of robotic feet
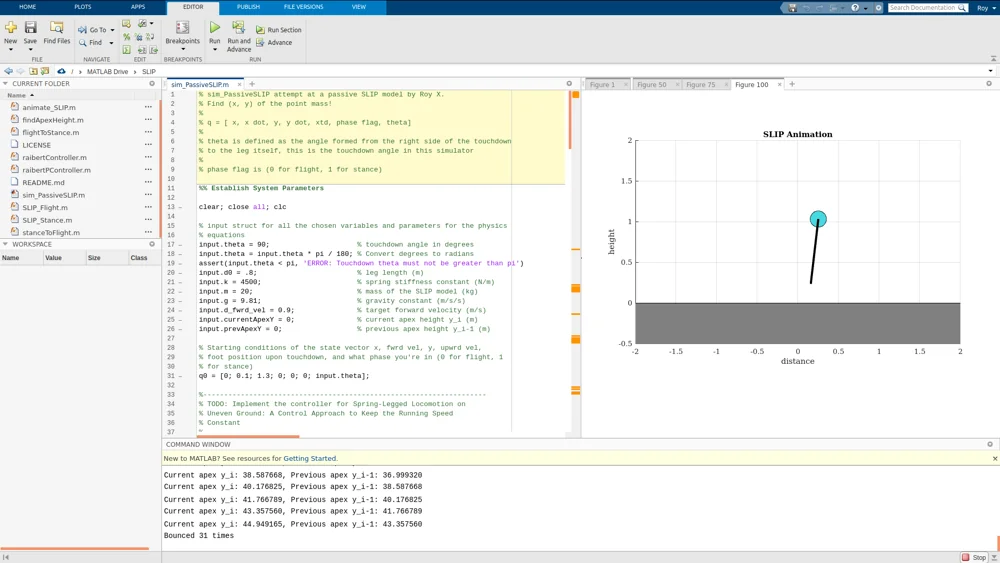
Spring Loaded Inverted Pendulum
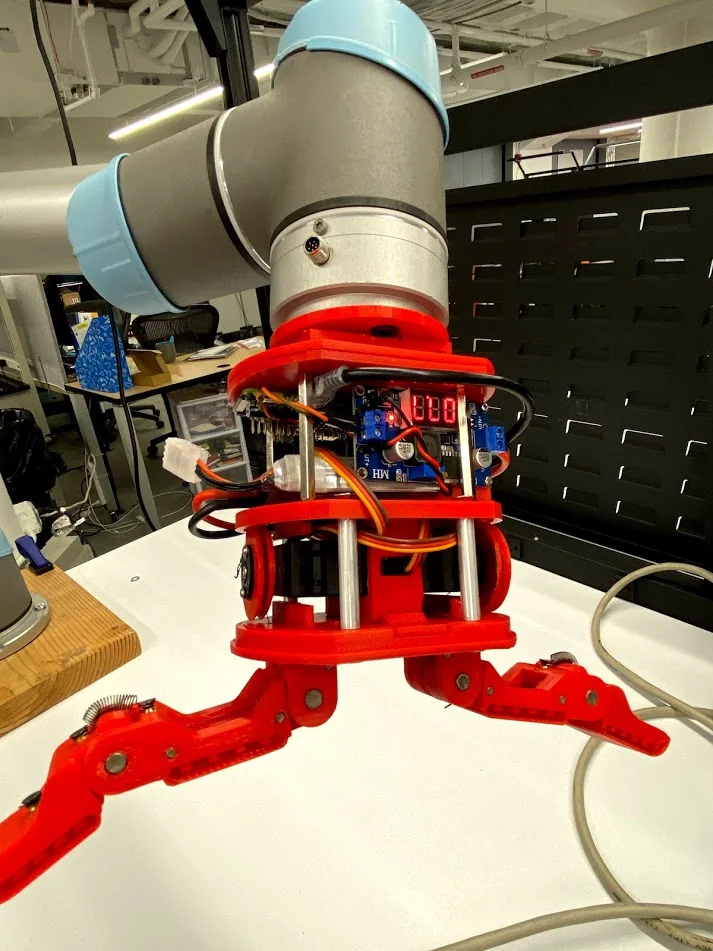
Modified T42 Gripper from Yale for MassRobotics use
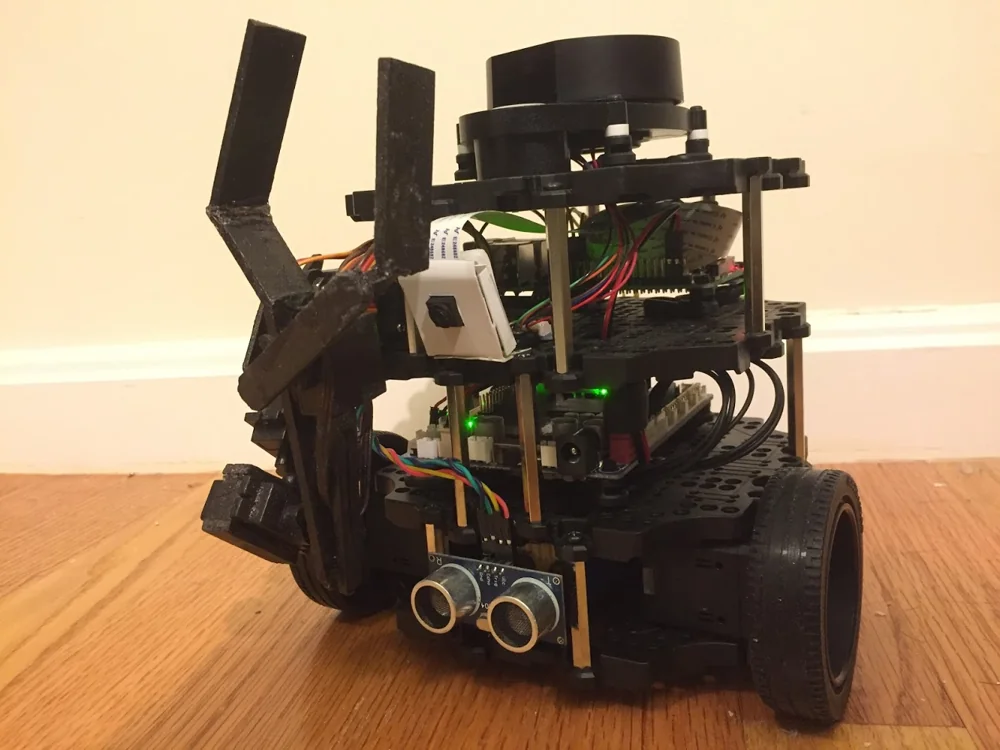
Custom turtlebot3 robot

Robotics Team
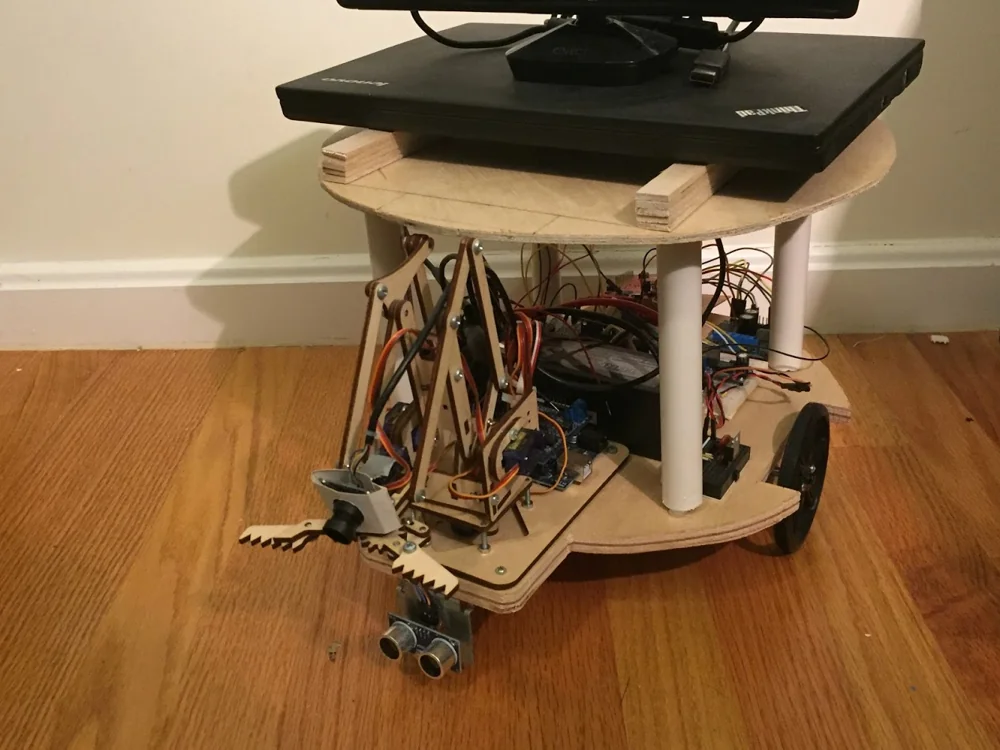
Custom Robot for SLAM, object recognition, and object manipulation